|
Chun Gu - 顾淳 email / github / google scholar I'm a third-year Ph.D. student at Fudan University and Shanghai Innovation Institute (SII), advised by Prof. Li Zhang. I work on embodied intelligence by building complete robot systems. That includes low-level whole-body control for humanoids and higher-level systems for manipulation and navigation. My earlier work was in 3D computer vision and graphics, mostly on 3D reconstruction. |
|
Publications & Projects |
|
X-WBC: A Cross-Embodiment Foundation Model for Humanoid Whole-Body Control
Juntong Zhang, Chun Gu, Li Zhang CoRL, 2026 arXiv / project page / github A shared motion Transformer and robot-specific adapters enable whole-body control across humanoids with different morphologies. |
|
|
X-World: Transferring Video Priors to Variable-View Robot Control
Chun Gu, Xiaofei Wei, Yiming Chen, Juntong Zhang, Li Zhang arXiv, 2026 arXiv / project page / github X-World transfers pretrained video features to robot control across camera configurations and action spaces, with experiments on real dual-arm manipulation tasks. |
|
|
Training in Deployment: Human-in-the-loop Online Post-Training for Robot Manipulation
Chun Gu*, Xiaofei Wei*, Yiming Chen, Bozhou Zhang, Juntong Zhang, Xiatian Zhu, Li Zhang arXiv, 2026 arXiv / project page / github TIDE fine-tunes a robot manipulation policy during deployment using both human interventions and autonomous robot experience. |
|
|
SMR: Learning streaming motion retargeting for humanoids from human semantic
Chun Gu, Juntong Zhang, Jingyu Li, Li Zhang arXiv, 2026 arXiv / project page / github SMR trains a causal motion retargeter on physics-based expert trajectories to produce humanoid control references from streaming human motion. |
|
|
Forward Dynamics Models
Zipei Ma, Junzhe Jiang, Jiahui Zhang, Juntong Zhang, Chun Gu, Bozhou Zhang, Jiankang Deng, Xiatian Zhu, Li Zhang arXiv, 2026 arXiv / project page / github Forward Dynamics Models use future-state prediction to supervise robot policies during training and generate actions directly at deployment. |
|
|
From Imagined Futures to Executable Actions: Mixture of Latent Actions for Robot Manipulation
Yajie Li*, Bozhou Zhang*, Chun Gu, Zipei Ma, Jiahui Zhang, Jiankang Deng, Xiatian Zhu, Li Zhang ICML, 2026 arXiv / ICML / project page / github / checkpoints MoLA learns complementary motion, depth, and semantic cues from predicted visual transitions to turn imagined futures into robot actions. |
|
|
NavOL: Navigation Policy with Online Imitation Learning
Xiaofei Wei*, Chun Gu*, Li Zhang ICML, 2026 arXiv / ICML / project page / github / models & data NavOL trains a visual navigation policy on its own simulated rollouts with corrections from a global planner, then deploys it on a real quadruped without fine-tuning. |
|
|
Reinforcing Action Policies by Prophesying
Jiahui Zhang*, Ze Huang*, Chun Gu, Zipei Ma, Li Zhang arXiv, 2025 arXiv / project page / github ProphRL uses an action-conditioned video world model as a simulator to improve flow-based robot policies through reinforcement learning. |
|
|
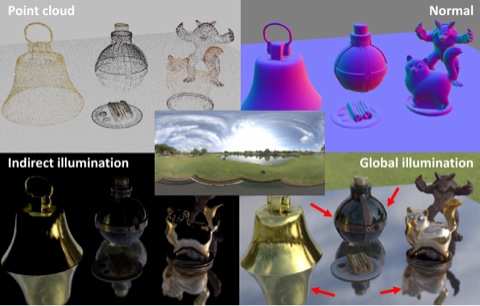
Inter-Reflective Gaussian Splatting for Robust and Efficient Inverse Rendering
Chun Gu, Xiaofei Wei, Zixuan Zeng, Yuxuan Yao, Li Zhang arXiv, 2026 arXiv IRGS++ models inter-reflections in scenes with glossy and metallic materials using differentiable 2D Gaussian ray tracing. It uses mesh-based visibility queries to speed up relighting. |
|
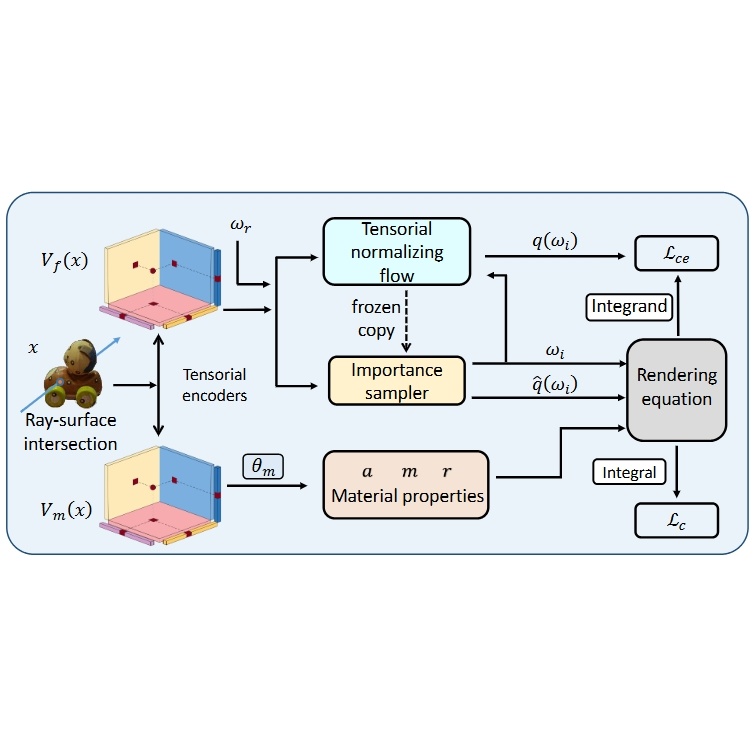
TensoFlow: Tensorial Flow-based Sampler for Inverse Rendering
Chun Gu, Xiaofei Wei, Li Zhang, Xiatian Zhu, CVPR, 2025 arXiv / github In this paper, we introduce a spatially and directionally aware importance sampler for the rendering equation to accurately and flexibly capture the unconstrained complexity of a typical scene. |
|
IRGS: Inter-Reflective Gaussian Splatting with 2D Gaussian Ray Tracing
Chun Gu, Xiaofei Wei, Zixuan Zeng, Yuxuan Yao, Li Zhang, CVPR, 2025 arXiv / project page / github 
In this paper, we introduce inter-reflective Gaussian splatting for inverse rendering. We apply the full rendering equation without simplification and compute incident radiance on the fly using the proposed differentiable 2D Gaussian ray tracing. |
|
|
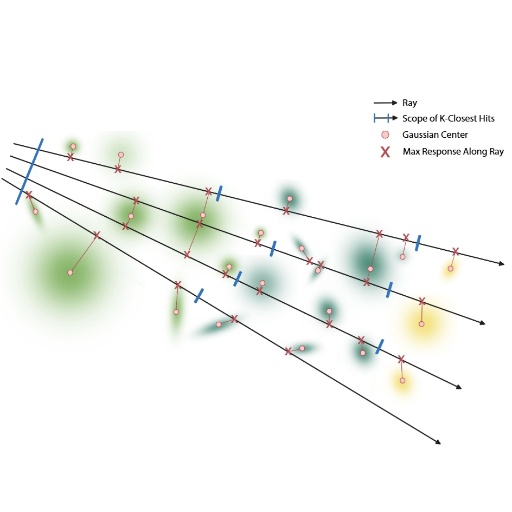
An implementation of 3D Gaussian Ray Tracing
Chun Gu Open-source Project github  /
github (gstracer backend) 
An implementation of 3D Gaussian Ray Tracing, inspired by the work 3D Gaussian Ray Tracing: Fast Tracing of Particle Scenes. |
|
GS-LiDAR: Generating Realistic LiDAR Point Clouds with Panoramic Gaussian Splatting
Junzhe Jiang, Chun Gu, Yurui Chen, Li Zhang ICLR, 2025 arXiv / github 
A novel framework for generating realistic LiDAR point clouds with panoramic Gaussian splatting. |
|
|
Ref-Gaussian: Reflective Gaussian Splatting
Yuxuan Yao*, Zixuan Zeng*, Chun Gu, Xiatian Zhu, Li Zhang ICLR, 2025 arXiv / project page / github 
A Reflective Gaussian splatting framework characterized with two components: (I) Physically based deferred rendering; (II) Gaussian-grounded inter-reflection. |
|
|
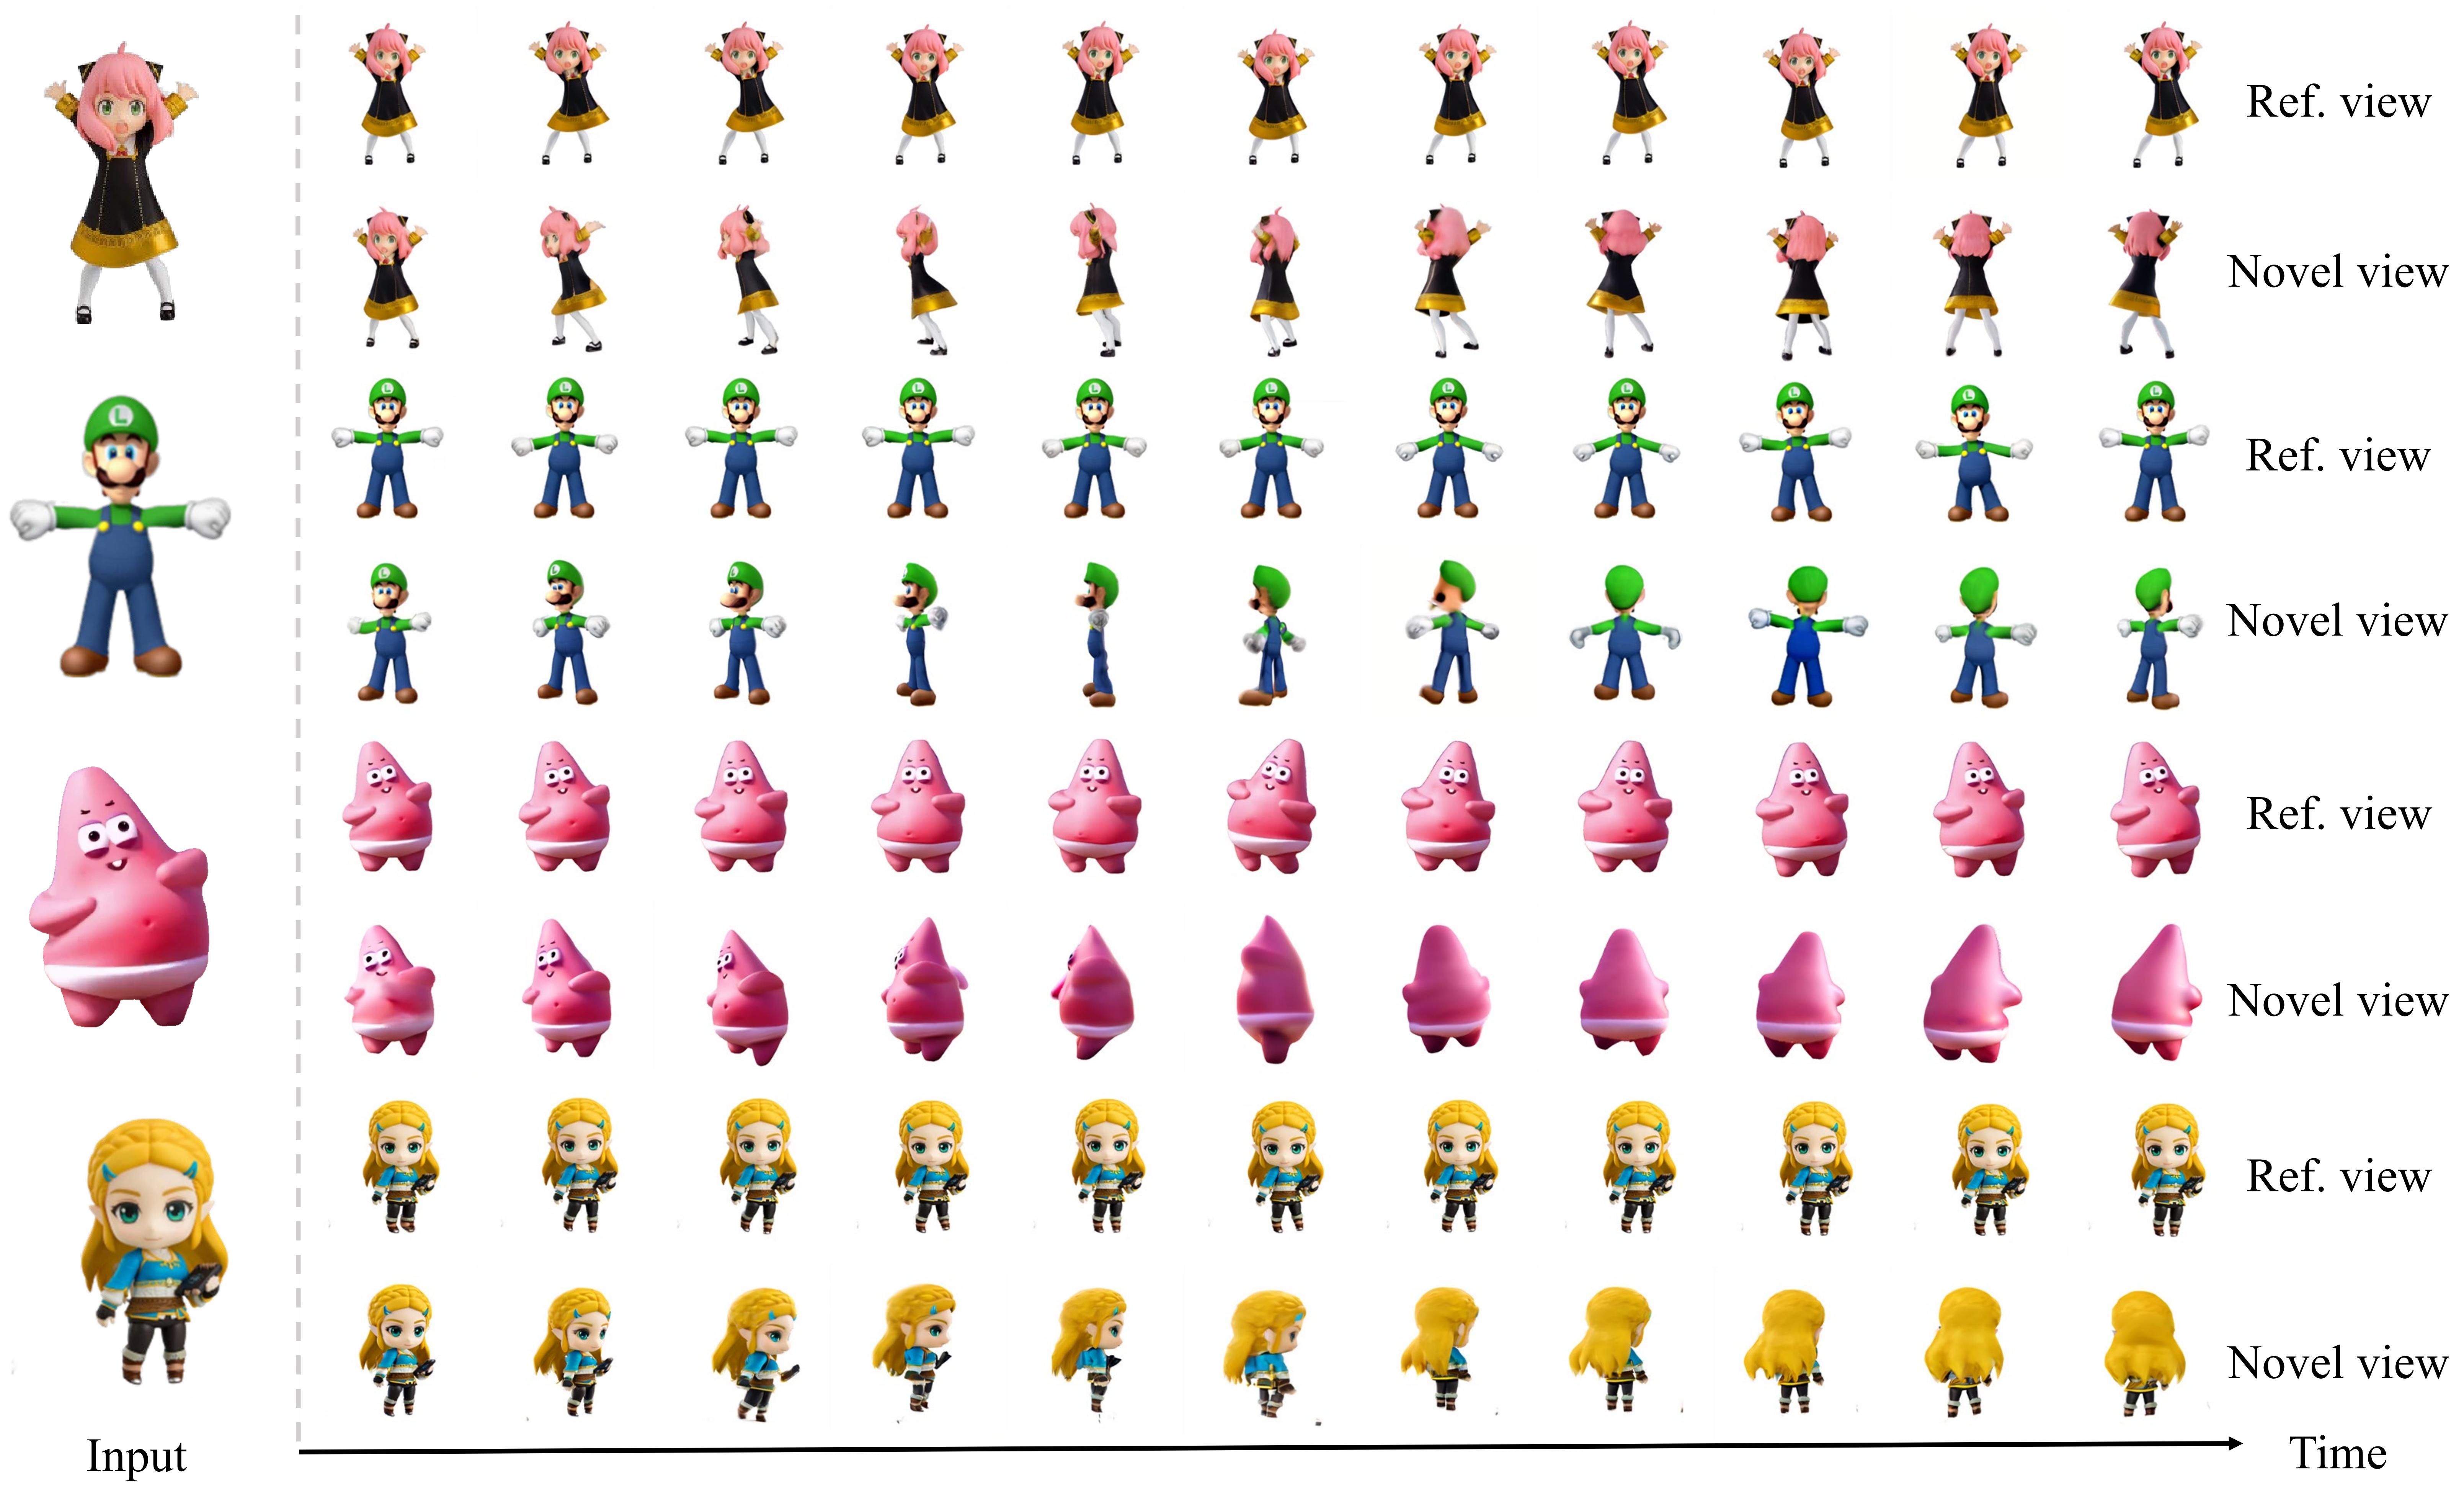
Diffusion²: Dynamic 3D Content Generation via Score Composition of Orthogonal Diffusion Models
Zeyu Yang*, Zijie Pan*, Chun Gu, Li Zhang ICLR, 2025 arXiv / github 
In this paper, we propose to achieve 4D generation from directly sampling the dense multi-view multi-frame observation of dynamic content by composing the estimated score of pretrained video and multi-view diffusion models that have learned strong prior of dynamic and geometry. |
|
Invited talk at Shenlanxueyuan on 3D generation with SDS
Chun Gu video / slides Providing a brief introduction to the progress in 3D generation using Score Distillation Sampling (SDS). |
|
Tetrahedron Splatting for 3D Generation
Chun Gu, Zeyu Yang, Zijie Pan, Xiatian Zhu, Li Zhang NeurIPS, 2024 (Spotlight) arXiv / project page / github 
Integrating surface-based volumetric rendering within a structured tetrahedral grid, utilizing tetrahedra for splatting. |
|
|
Periodic Vibration Gaussian: Dynamic Urban Scene Reconstruction and Real-time Rendering
Yurui Chen*, Chun Gu*, Junzhe Jiang, Xiatian Zhu, Li Zhang IJCV, 2026 journal article / arXiv / project page / github 
A unified representation model for large-scale dynamic urban scene reconstruction. |
|
|
Relightable 3D Gaussian: Real-time Point Cloud Relighting with BRDF Decomposition and Ray Tracing
Jian Gao*, Chun Gu*, Youtian Lin, Hao Zhu, Xun Cao, Li Zhang, Yao Yao ECCV, 2024 arXiv / project page / github 
A novel differentiable point-based rendering framework for material and lighting decomposition from multi-view images, enabling editing, ray-tracing, and real-time relighting of the 3D point cloud. |
|
|
Unofficial implementation of "Zip-NeRF: Anti-Aliased Grid-Based Neural Radiance Fields"
Chun Gu Open-source Project github 
An unofficial pytorch implementation of "Zip-NeRF: Anti-Aliased Grid-Based Neural Radiance Fields" based on multinerf. |
|
|
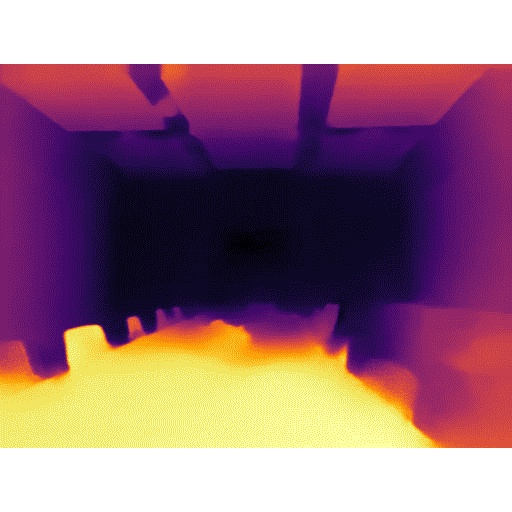
Single-view Neural Radiance Fields with Depth Teacher
Yurui Chen, Chun Gu, Feihu Zhang, Li Zhang ICLR workshop 2023 arXiv Combining the (coarse) planar rendering and the (fine) volume rendering to achieve higher rendering quality and better generalizations. A depth teacher net that predicts dense pseudo depth maps is used to supervise the joint rendering mechanism and boost the learning of consistent 3D geometry. |
|
The website template was borrowed from Jon Barron. |